Posts

Showing posts with the label Robotics

LAIR - A* Path Planning
Image
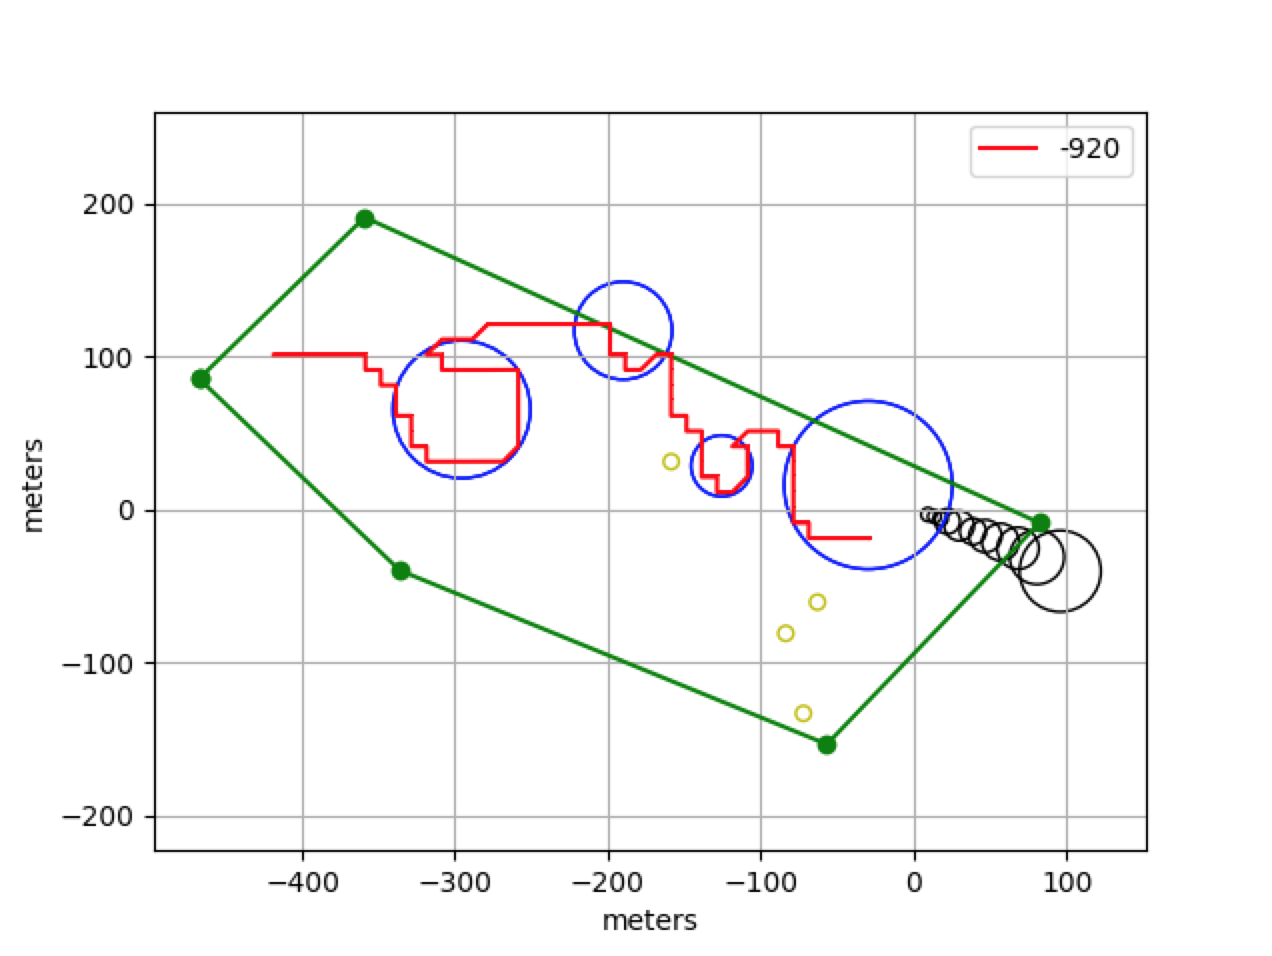
Hi everyone! My name is Alicia Lu, a rising sophomore working in the LAIR (Lab for Autonomous and Intelligent Robotics). This summer I have been working with my fellow classmates and Prof. Clark on developing a multi-AUV system to track sharks while simultaneously collecting marine habitat data.  My job on the path-planning team is to modify the classic A* search algorithm (often seen as an extension of the famous Dijkstra Algorithm) to include our expected functionalities: track sharks of fixed positions and cover as many new habitats as possible. I have developed two versions of path planning algorithms that can complete the listed tasks.  This post shows the simulation results from the algorithm that aims to explore as many new habitats as possible while trying to maximize time spent in each habitat. The longer time spent in a habitat implies longer trajectory length within a habitat. Figure 1 below illustrates a trajectory that starts at (-215.63, -5.89) and has a length o...
LAIR - Path Planning

Image
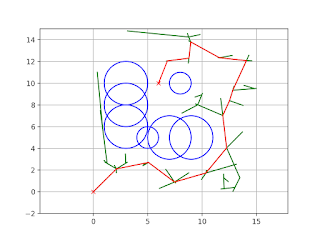
Hi Everyone, I am Linda Li, a rising sophomore from Harvey Mudd College. Over the past weeks, I have worked in Lab for Autonomous and Intelligent Robotics (LAIR) under the supervision of Prof Clark. I am excited to share some of my progress with you all. I am working on Shark Tracking with AUVs (Autonomous Underwater Vehicle) project, where we want to develop a multi-AUV system to track tagged sharks for a long period of time.  At the beginning of this summer, I explored and implemented path planning algorithms such that AUVs will be able to plan the optimal path from current positions to the target sharks while avoiding obstacles along the way. I focused on the Rapidly-exploring Random Tree (RRT) algorithm. This algorithm finds the path from the starting point to the goal by iterating the process of randomly choosing a point in the whole space, connecting this point with the closest point in the tree, and testing if the new subpath is collision-free with any obstacles until it hit...